Project Horizon
Hardware, 2026- Pilot controllerAn Arduino Nano reads two sticks and two switches and packs them into 7 bytes.
- Radio linkOne-way 2.4 GHz at 250 kbps, with a 16-bit CRC and our own checksum.
- Drone receiverA second Nano rejects corrupt packets and outputs six PWM channels.
- SBUS converterSix PWM channels become one SBUS stream.
- Flight controllerBetaflight runs the stabilisation loops and drives four motors.
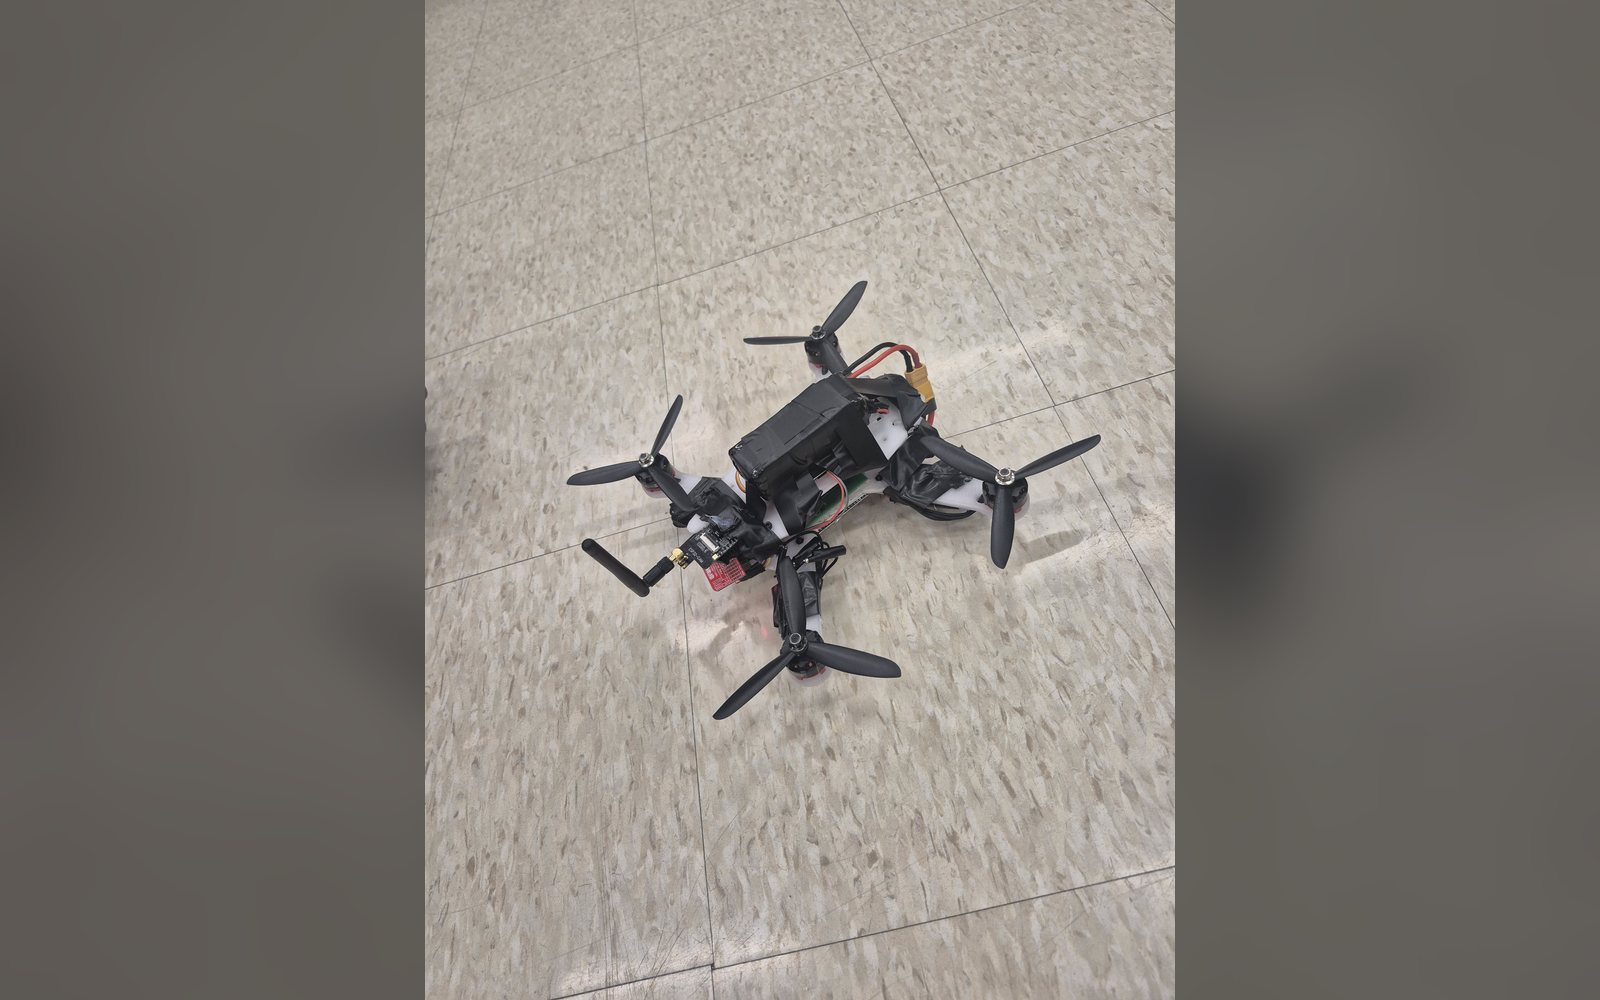
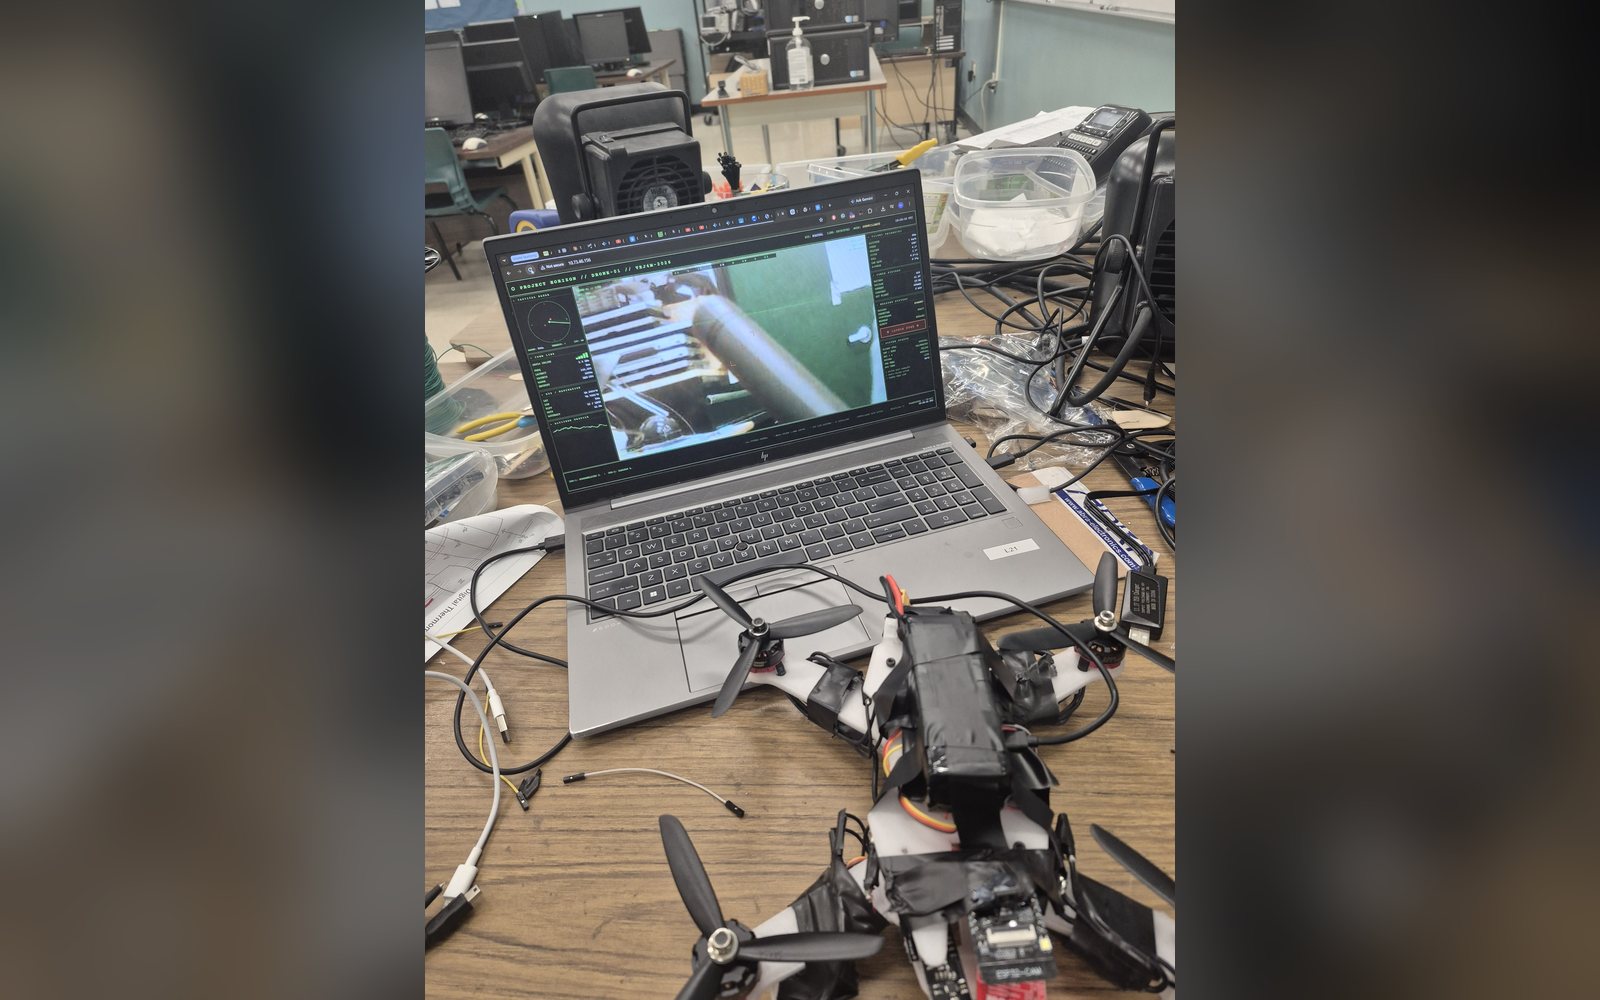
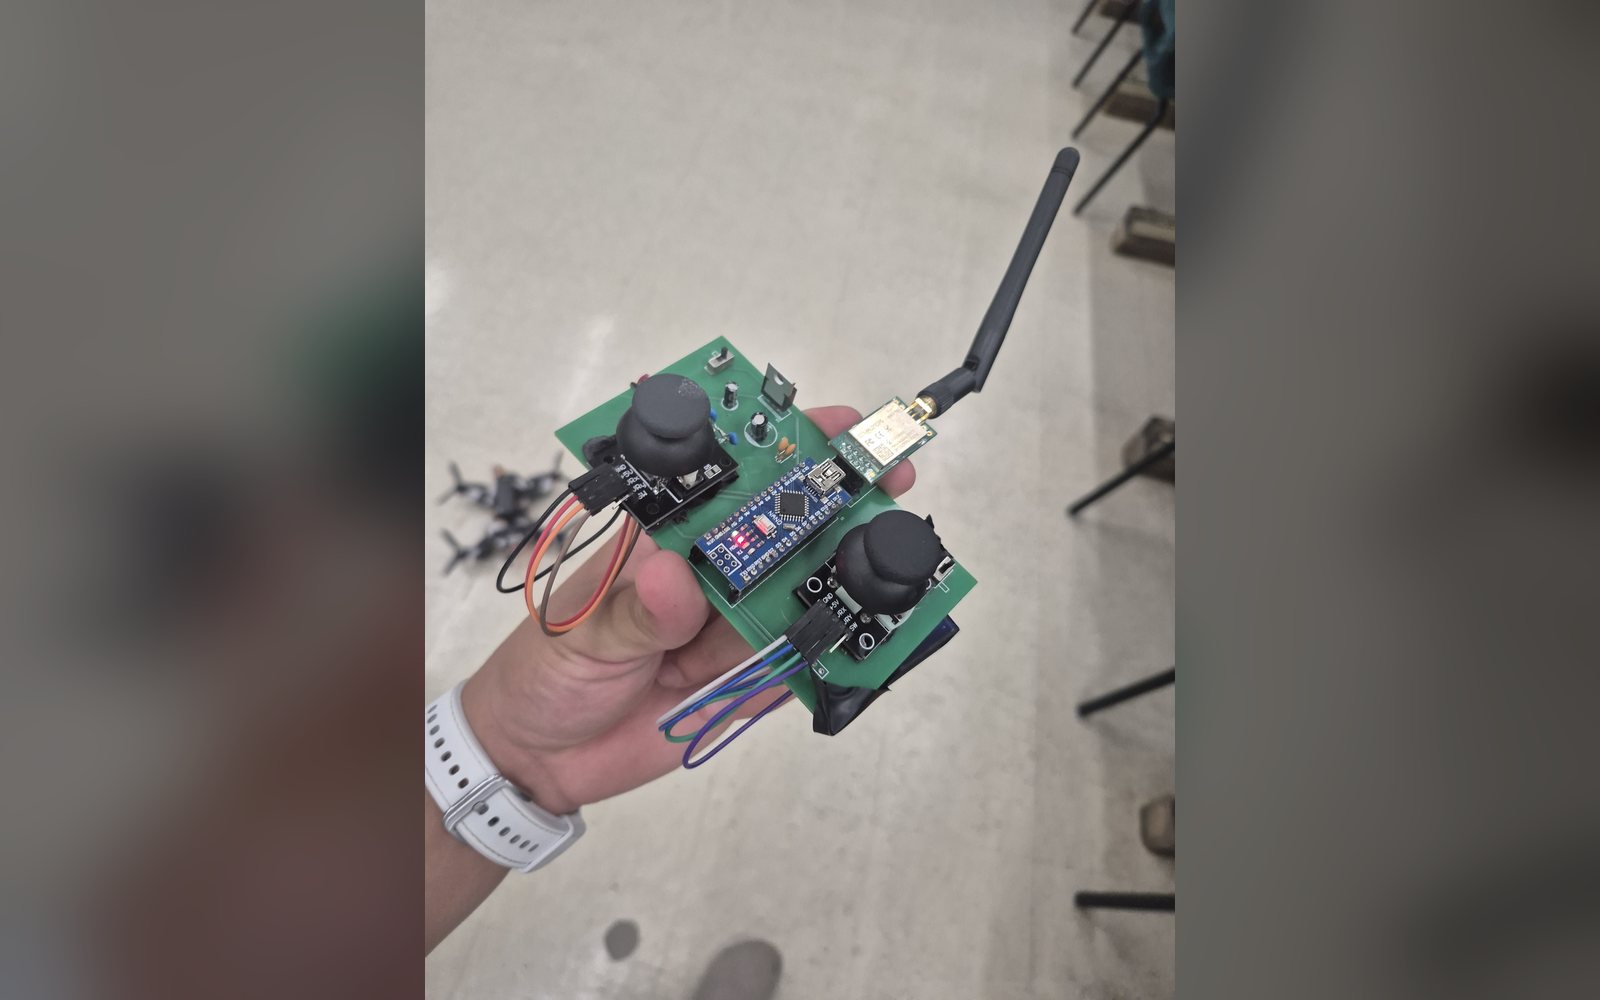
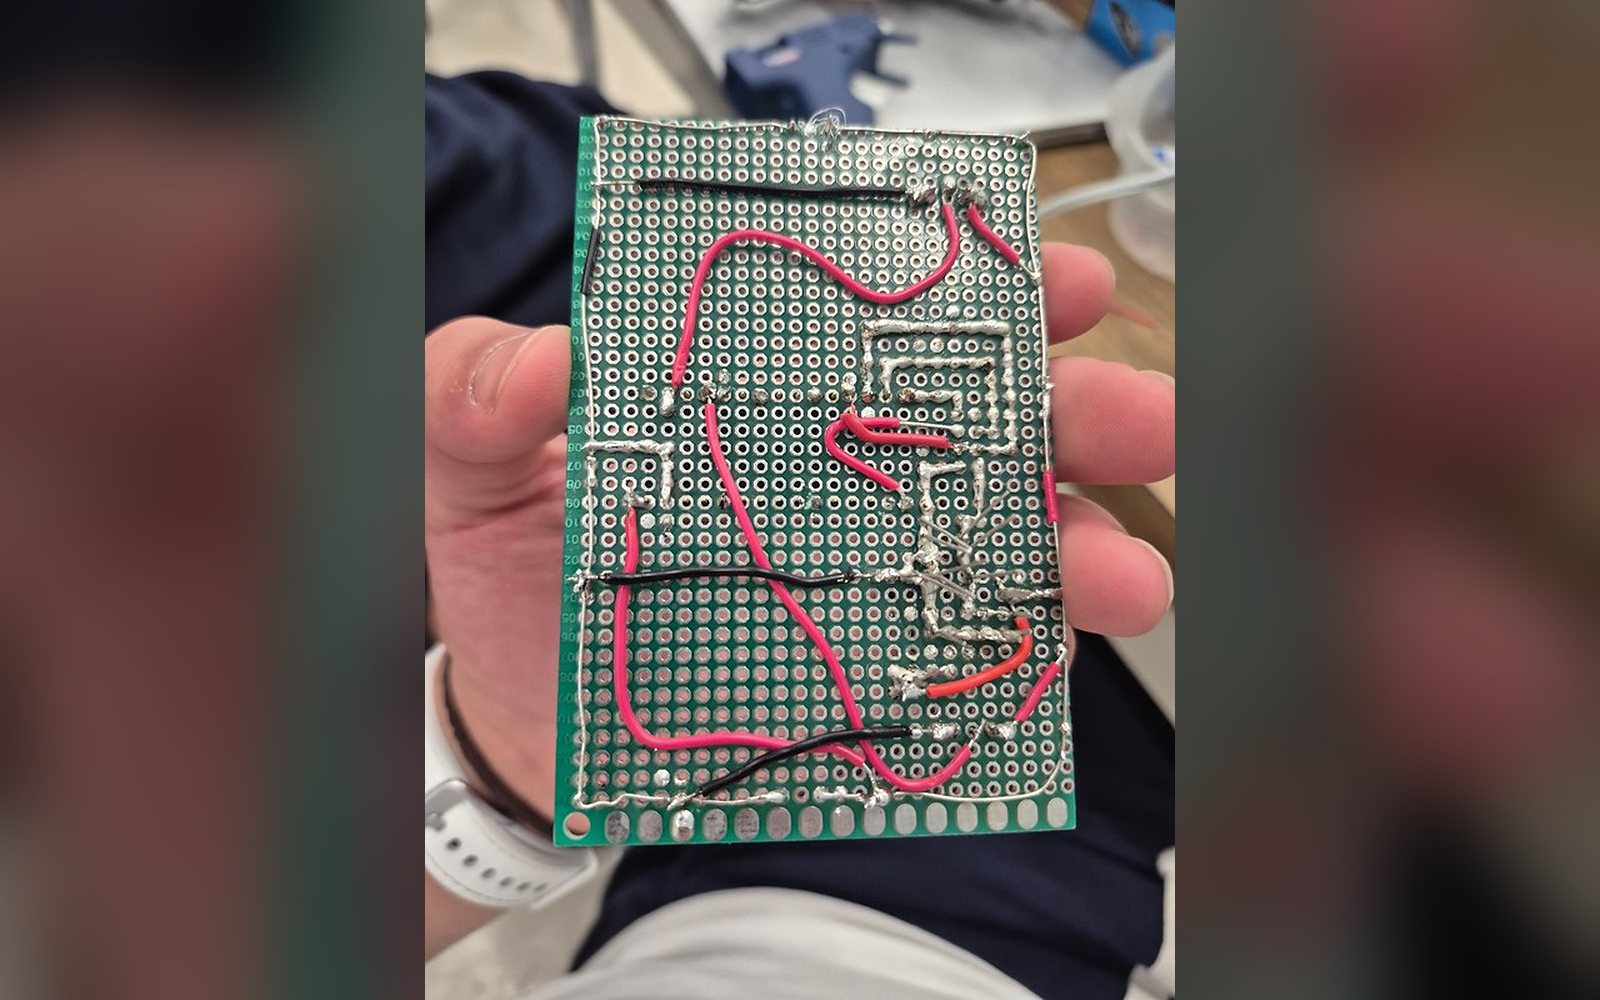
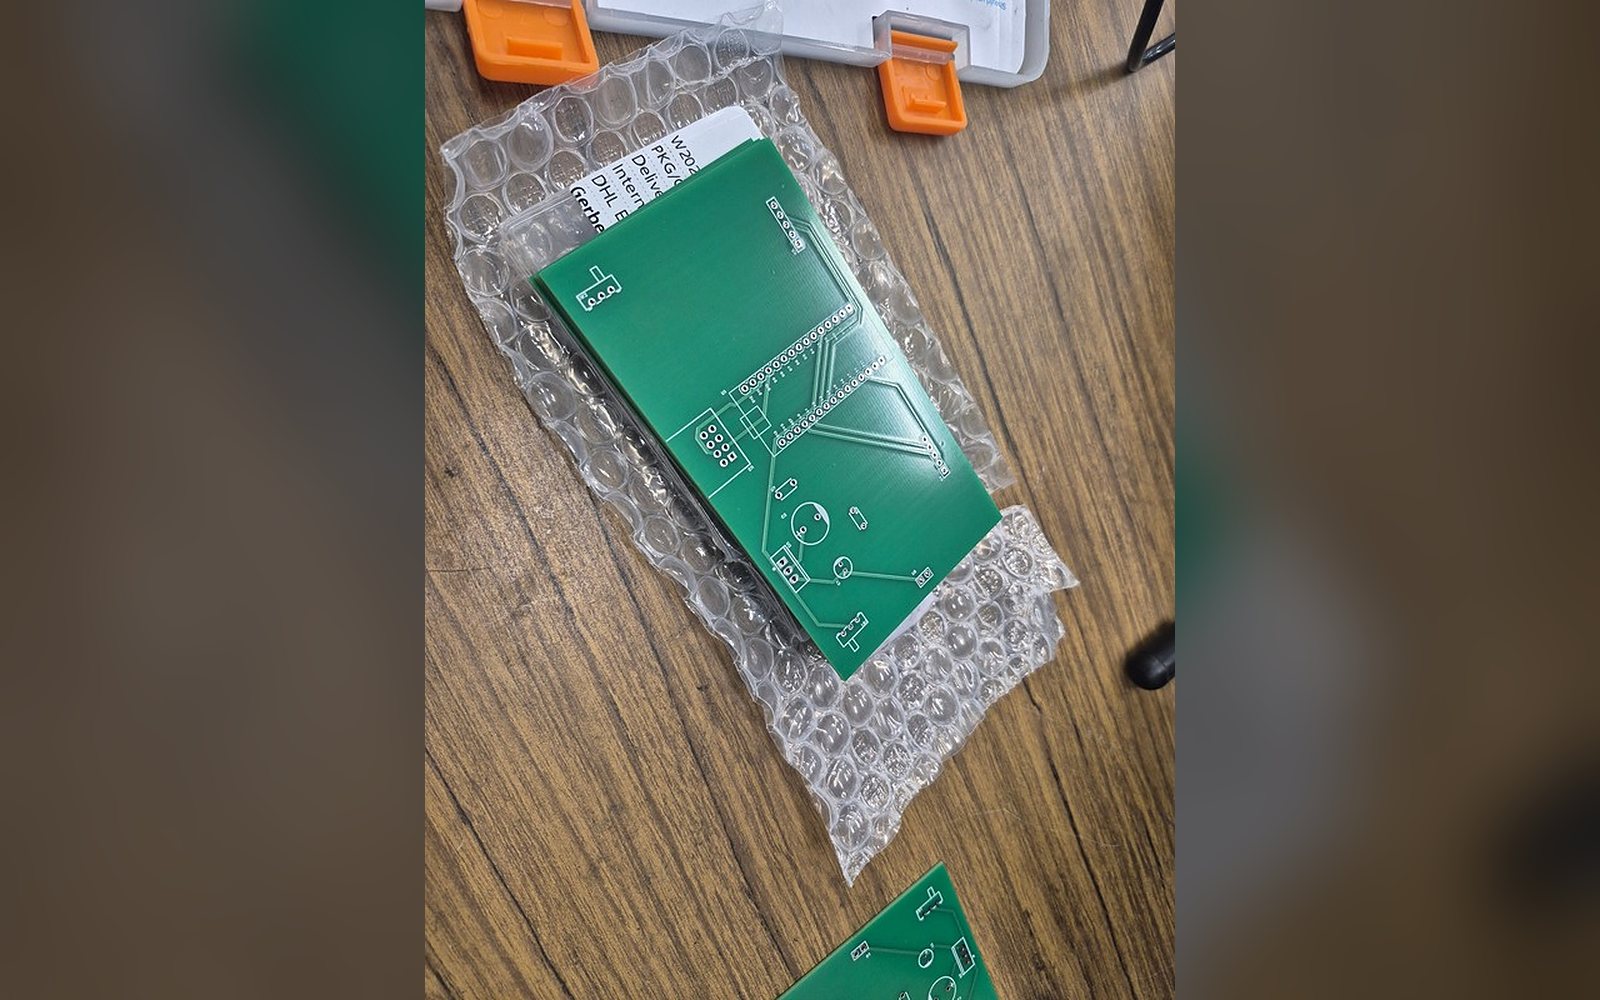
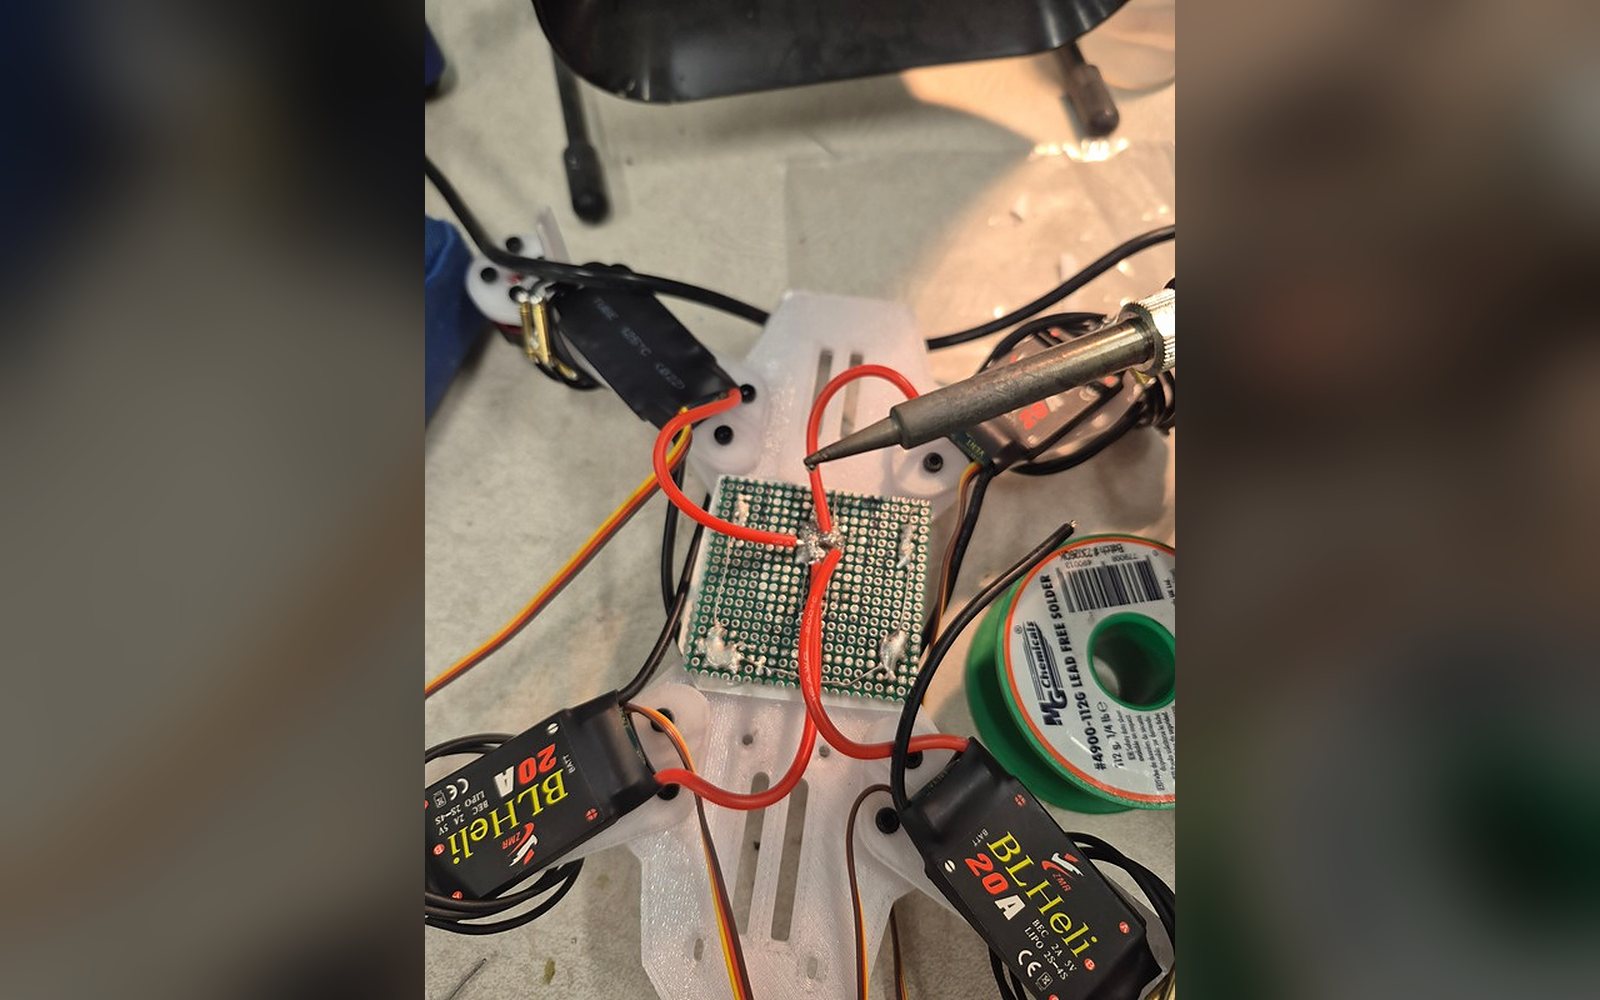
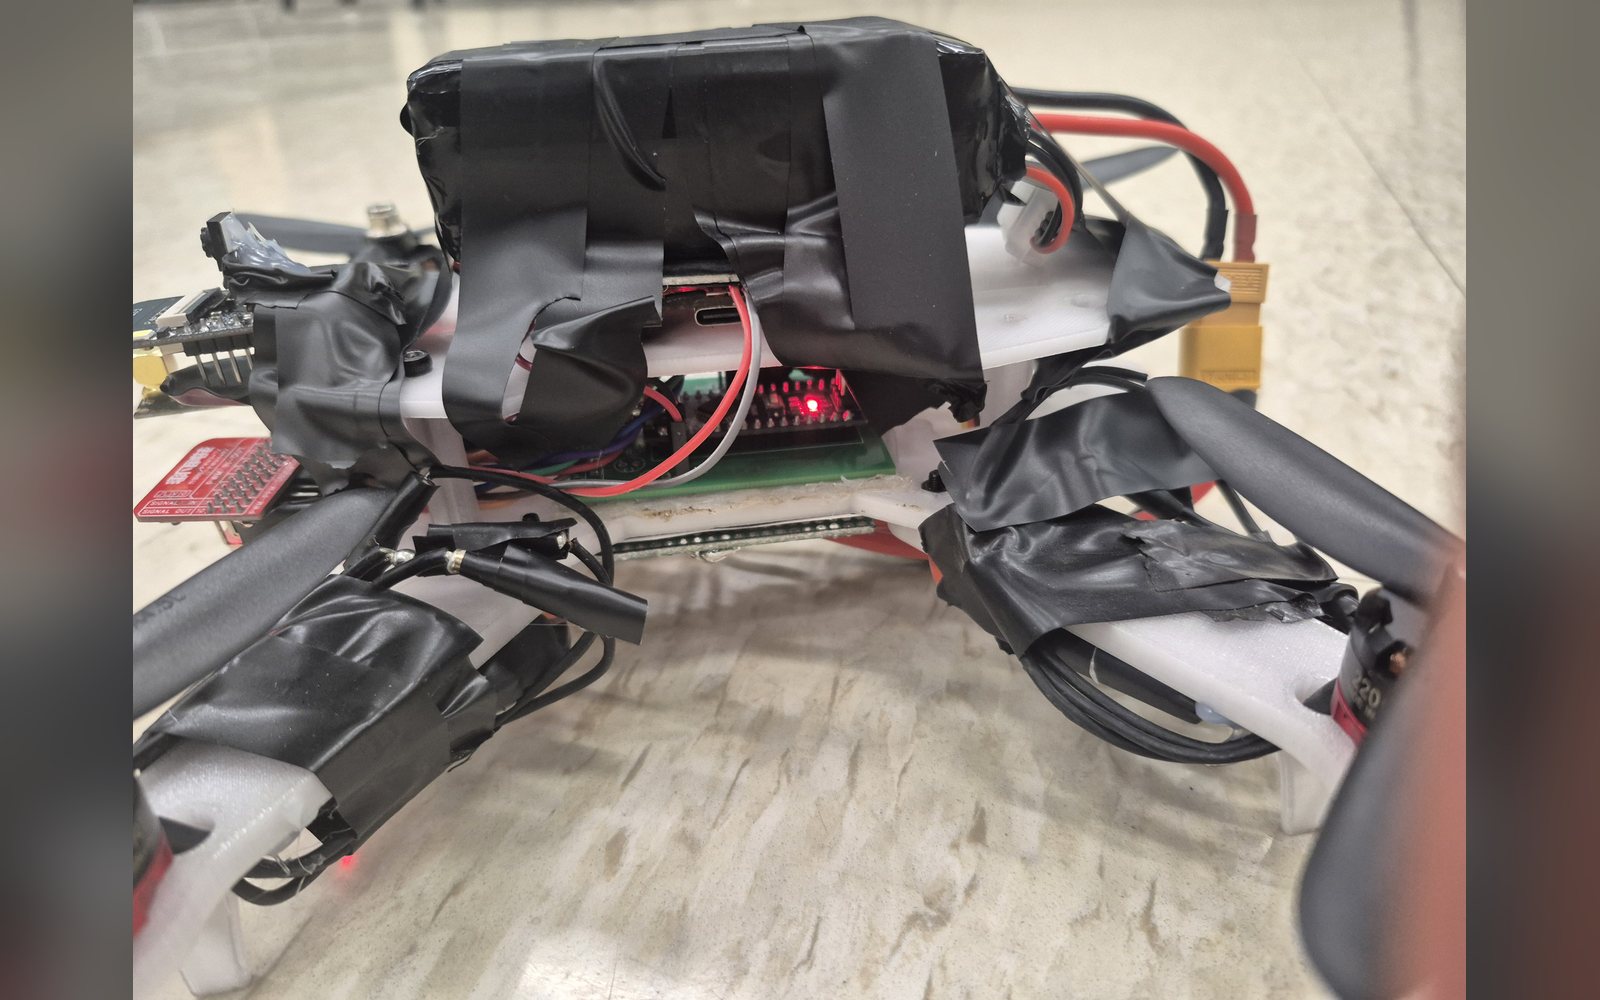
A 5-inch FPV quadcopter where every link in the control chain is ours, from the hand-soldered controller to the radio protocol.
- Problem
- Fly a drone with no store-bought radio, while motor noise kept corrupting packets and disarming it mid-test.
- What I built
- Our Grade 12 capstone, with Algasem Zabarah. I wrote the controller firmware.
- It reads the sticks and packs every command into 7 bytes
- An XOR checksum throws out corrupted packets
- A failsafe rides out dropouts and cuts the throttle after 1.2 s
- Hardest bugs
- Cold solder joints, a radio that wasn't detected, motors that looked connected but weren't, ESCs that couldn't speak DShot, and interference under load. We tracked down and fixed all five.
- Stack
- Arduino NanoNRF24L01ESP32-CAMBetaflightJLCPCB PCBs
- Result
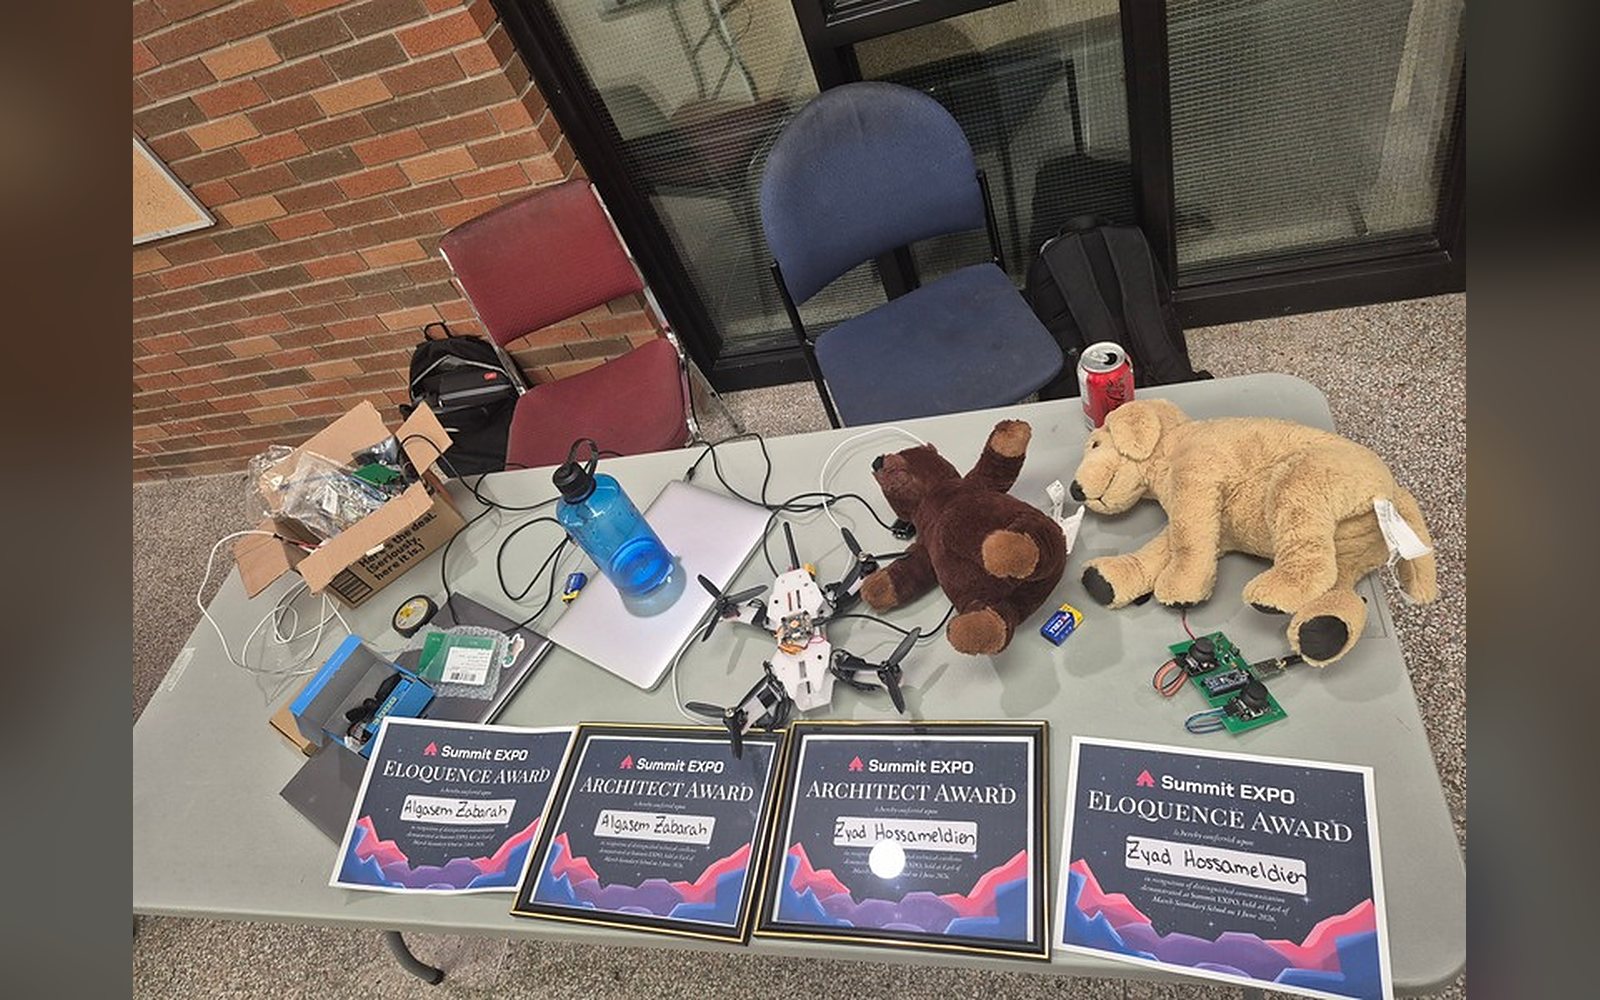
- A stable hover on our own controller, and the Architect and Eloquence Awards at the Summit EXPO.
- By the numbers
- 0 kits$200 total4 kg of thrust3 dead Arduinos1 semester